Home System Architecture Reflection Milestone 1 Milestone 2

NEATO TAG

CompRobo 2025

Lily Wei, Zara Coakley, Kelsey McClung, Brooke Wager, Tchenzie Guichette, Brenna O'Donnell

Project Overview

Welcome to Neato Tag! Beginning this project, we wanted to be able to play tag with the Neatos around our school’s academic building. We imagined two approaches to achieve this: the first using machine vision for the "it" Neato to detect its target, and the second localizing both Neatos on a known map using a particle filter and communicating the Neatos’ coordinates between each other.
In the end we completed our machine vision approach, and can play tag with two Neatos. The “it” Neato, or chaser Neato, is controlled by color detection machine vision, and the escaper Neato is controlled by a user with teleop (keyboard input) controls. When the escaper Neato gets tagged, the controls of the two Neatos swap, and the game continues.
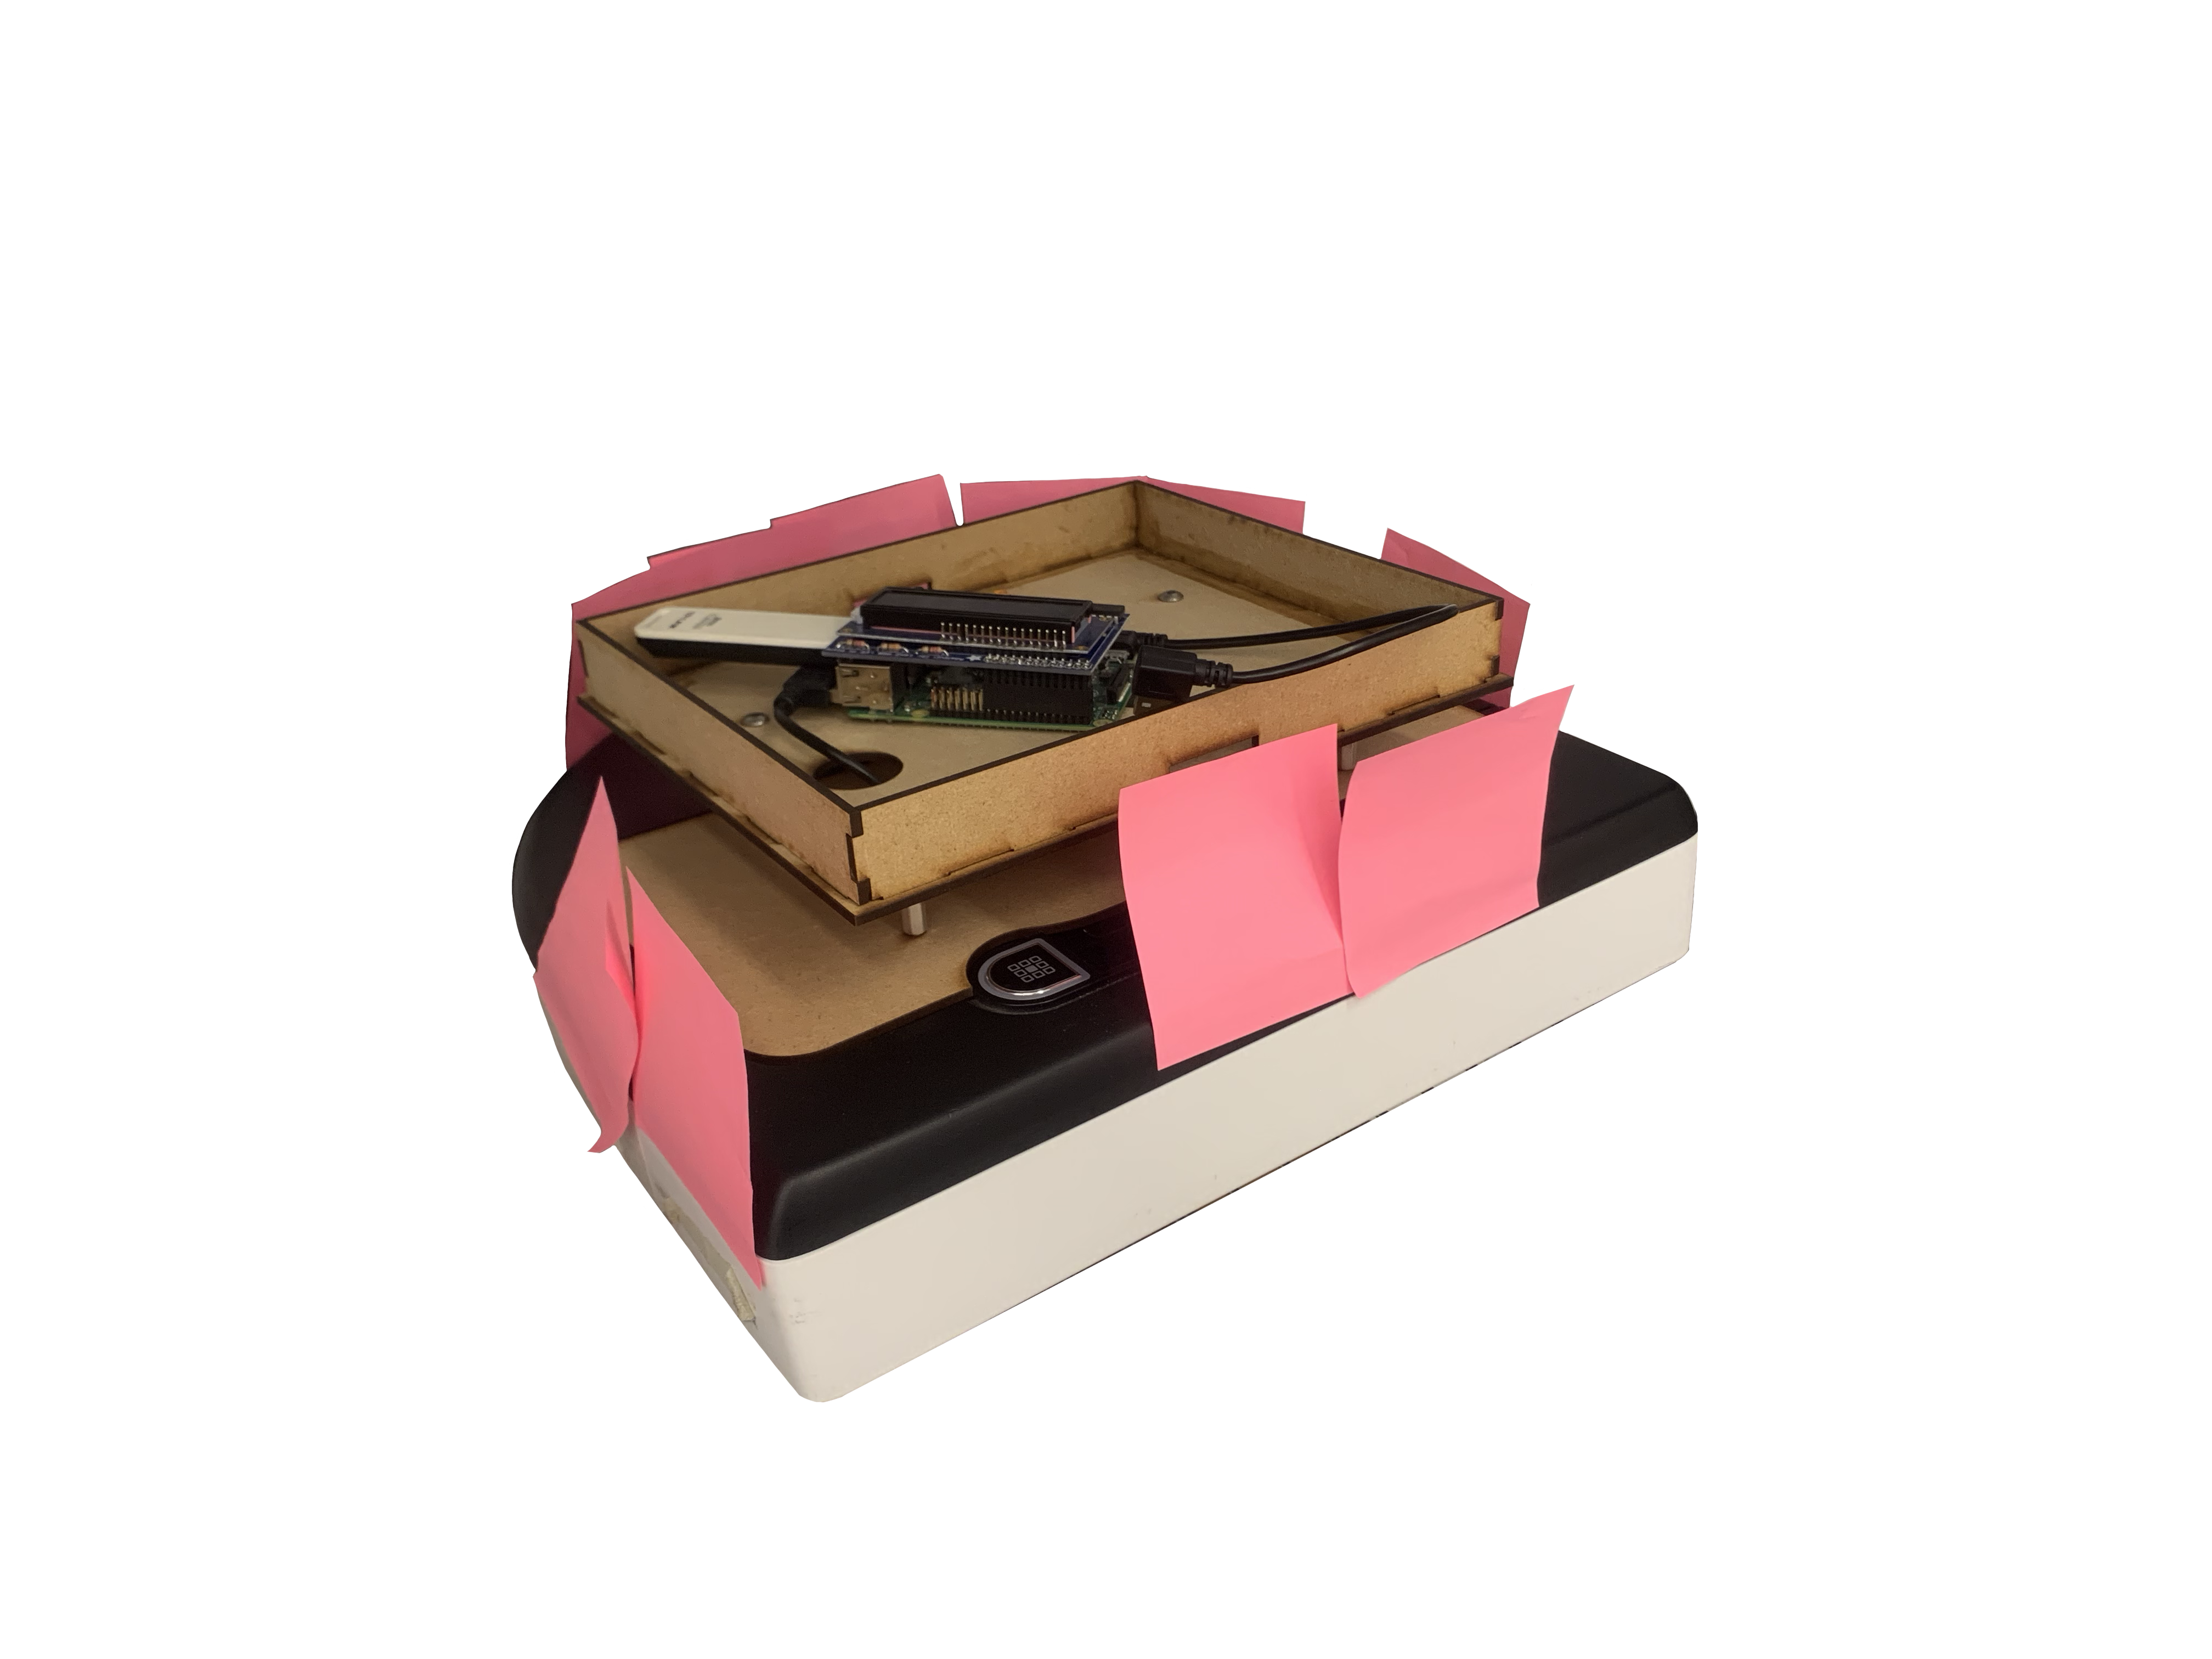
neato robot with sticky notes attached

Demonstration

Who We Are

We are a team of 6 students taking Computational Robotics at Olin College of Engineering. For our final project, we wanted to combine our learnings from previous projects throughout the semester, such as robot localization and machine vision, with concepts new to us, such as programming multi-robot systems.

System Overview

For this project, we split up into three subteams:
Machine Vision (Brooke and Lily): The machine vision subteam was focused on developing a machine vision pipeline that allows the chaser Neato to track and chase after the runner Neato. After developing the pipeline, we integrated our code with the Multi-Neato team to make the Neatos swap chaser and runner upon a tag.
Localization (Tchenzie and Zara): The localization subteam's goal was to create a system that allows Neatos to track their own poses within a known map and then publish those poses to each other. This allows the chaser Neato to follow the runner even when it can’t see it.
Multi-Neato and Integration (Brenna and Kelsey): The multi-Neato subteam worked on setting up the infrastructure for two Neatos to be controlled from one laptop. After achieving this they transitioned to working on integration between multi-Neato, localization, and machine vision subteams.